SCENARIO IN FOCUS
Bipedal robot inspection at hydropower stations
A research pilot for complex hydropower passages and human-height cabinets, combining multimodal sensing, VR teleoperation, virtual–physical training and controlled operation.
Request configuration adviceFor plans and project enquiries, contact:
610015486@163.com · 18611193215 ·
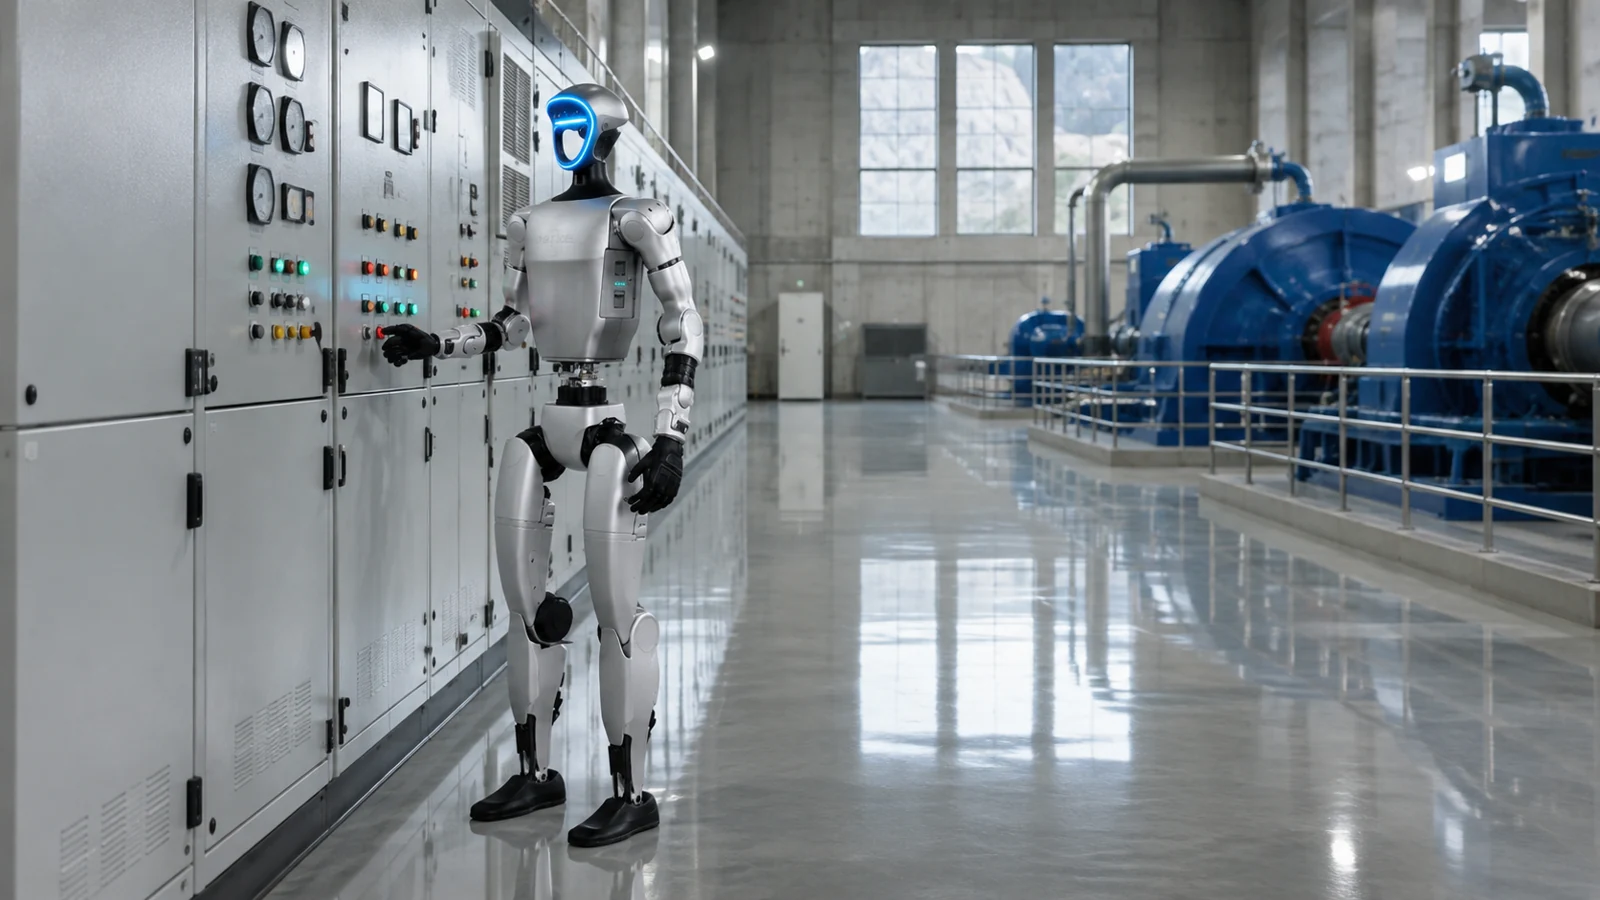 Application / concept illustration
Application requirements
Multiple levels, stairs and dense equipment complicate inspection routes. Autonomous travel, meter reading and anomaly review must fit one workflow.
Concept design
VR teleoperation data capture
Digital twins and SIL/HIL validation
Parametric cabinet-operation skill templates
Implementation considerations
Validate against terrain, communication coverage, equipment readings and anomaly samples. The robot, sensor payload and safety takeover setup depend on the site's technical agreement.
Source: 11水电站双足具身智能巡检整体解决方案V1.9.pptx. Images illustrate applications or concepts from the original material.
PROJECT INQUIRYTake your field requirements
Take your field requirements
into the next stage of planning.
Share the workpiece, site layout and target cycle time to discuss product selection, system configuration and validation.