CONTROLLED SHARPS SORTING
Controlled robotic sorting of medical sharps
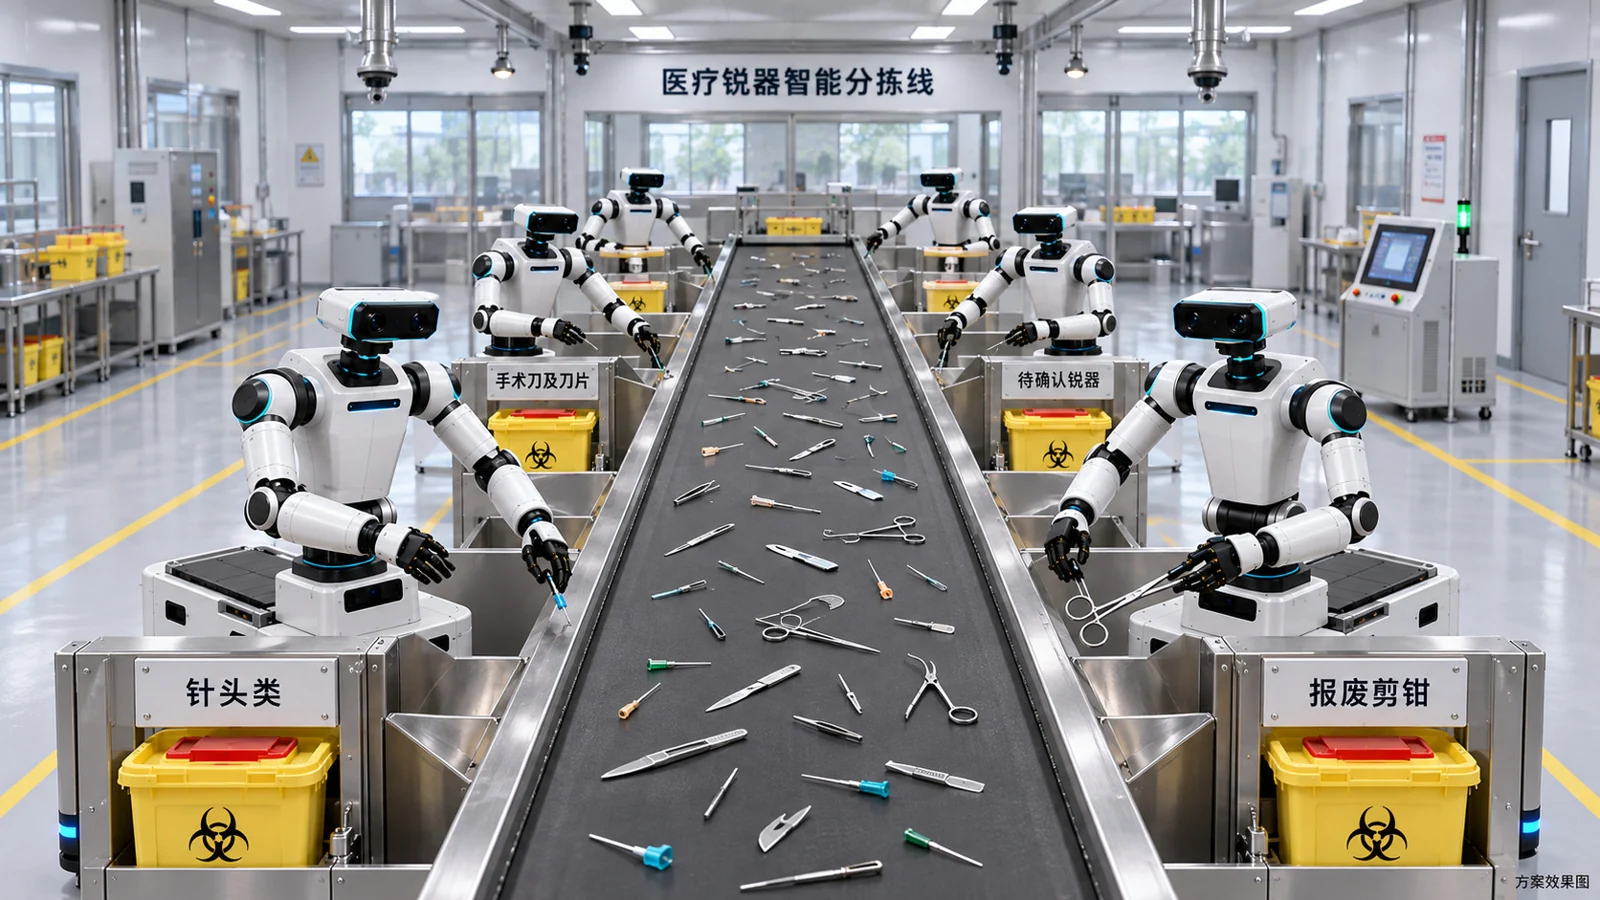
The sharps proposal is restricted to controlled loose items confirmed for disposal under an approved process. Existing medical-waste containers remain intact for whole-container handover. Reusable or unidentified items are excluded.
Request configuration adviceFor plans and project enquiries, contact:
610015486@163.com · 18611193215 ·
 Application / concept illustration
Embodied Intelligence site editor · Content reviewed
Conditions to establish first
- Incoming-item classification and loose-item process approval
- Gripper and container verification
- Shared-space exclusion and exception isolation
- Nature of the source material
- Controlled-application product proposal
- Configuration and pricing
- The source provides no verifiable current quotation. Confirm pricing against the site's task, configuration and validation scope.
- Conditions and limits of use
- Material already in medical-waste containers remains packaged and is not emptied onto the belt. Reusable instruments and unidentified, radioactive, special pharmaceutical or chemical waste are excluded.
- Evidence still needed
- No specific facility approval or measured prototype-performance evidence was supplied. Accuracy and cycle times are proposed validation targets.
Interpreting numbers in the material
The material defines four engineering sorting streams. Sorting does not change medical-waste classification; only approved in-scope items may be processed.
The original robot concept targets a 5 kg payload per arm including the end effector. This is not a final selection or acceptance value.
Sources and how to use them
20医疗废弃锐器机器人分拣_产品解决方案1.8.pptx
This is a summary of the original proposal, not a claim that the site editor has manufactured, sold or delivered the equipment. Check configuration, engineering targets and measured results separately.
From a concept to field validation ↗Problems addressed
- Risk from staff contact with sharps
- Thin needles, reflections and damaged samples are hard to recognize
- Incomplete records of classification and destination
Core capabilities and configuration
Specialized fixtures and low-level transfers
Four collection streams: needles, blades, scissors/forceps, and items requiring review
Verify receiving containers and confirm placement
Batch, exception and handover-destination traceability
Applications
Approved, protected and controlled facilitiesSorting of discarded needlesDiscarded blades, scissors and forcepsWhole-container medical-waste handover
Task workflow
01 · Verify incoming classification02 · Confirm process approval03 · Controlled feeding04 · Recognize and assign tasks05 · Robotic placement06 · Confirm placement07 · Package and hand over
From concept to site
Material already in medical-waste containers remains packaged and is not emptied onto the belt. Reusable instruments and unidentified, radioactive, special pharmaceutical or chemical waste are excluded.
EXPLORE MORE
Related products and systems
 Inspection and sorting
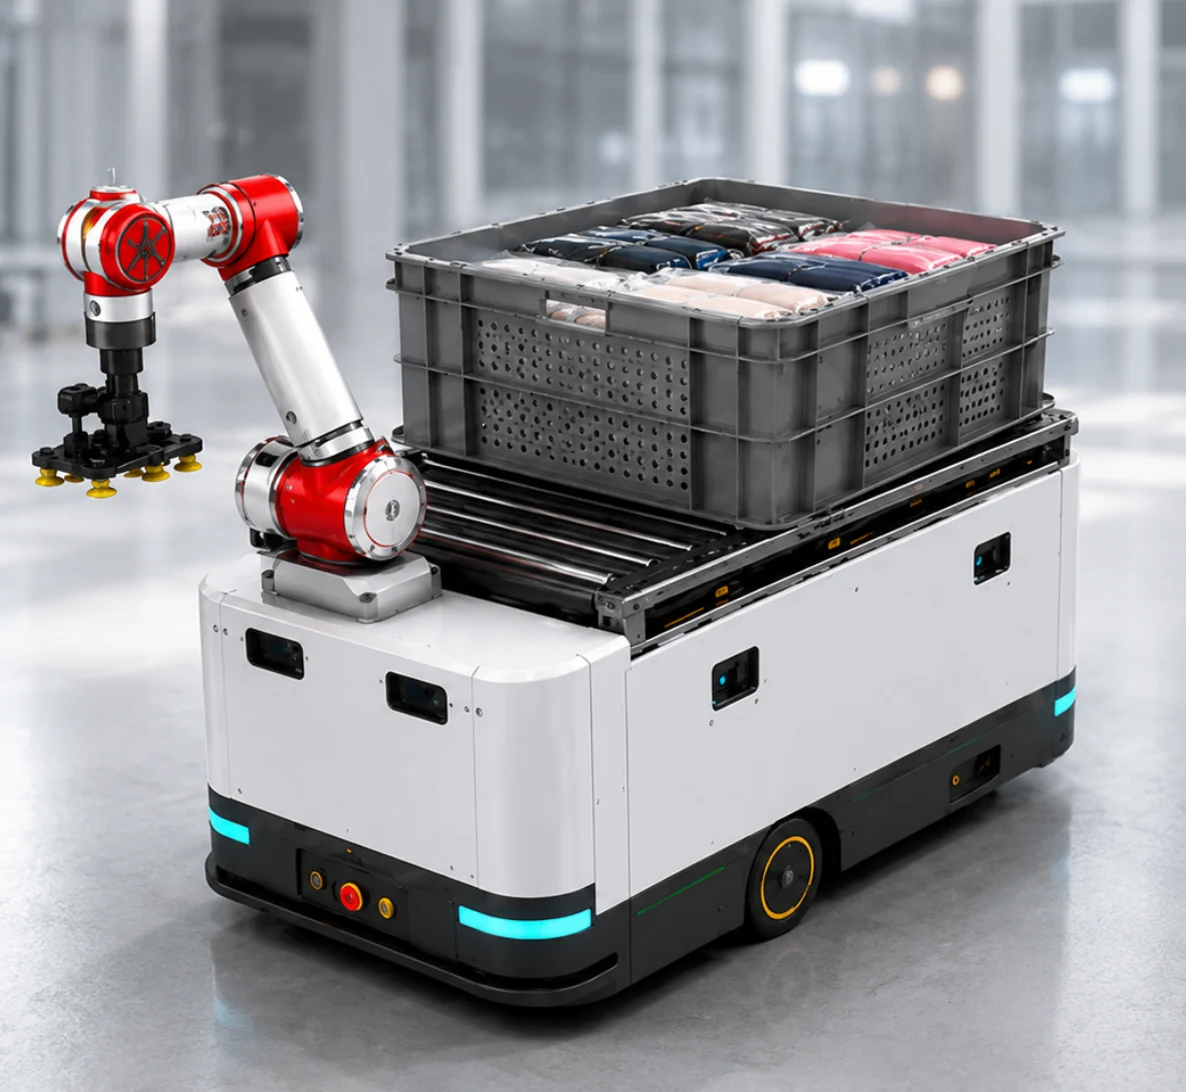
Flexible garment sorting
An open carton matrix, mobile-manipulator AGV and compliant vacuum-gripping arm identify, pick, transport and consolidate garment packages across sizes and colors.
View capabilities and conditions of use
 Inspection and sorting
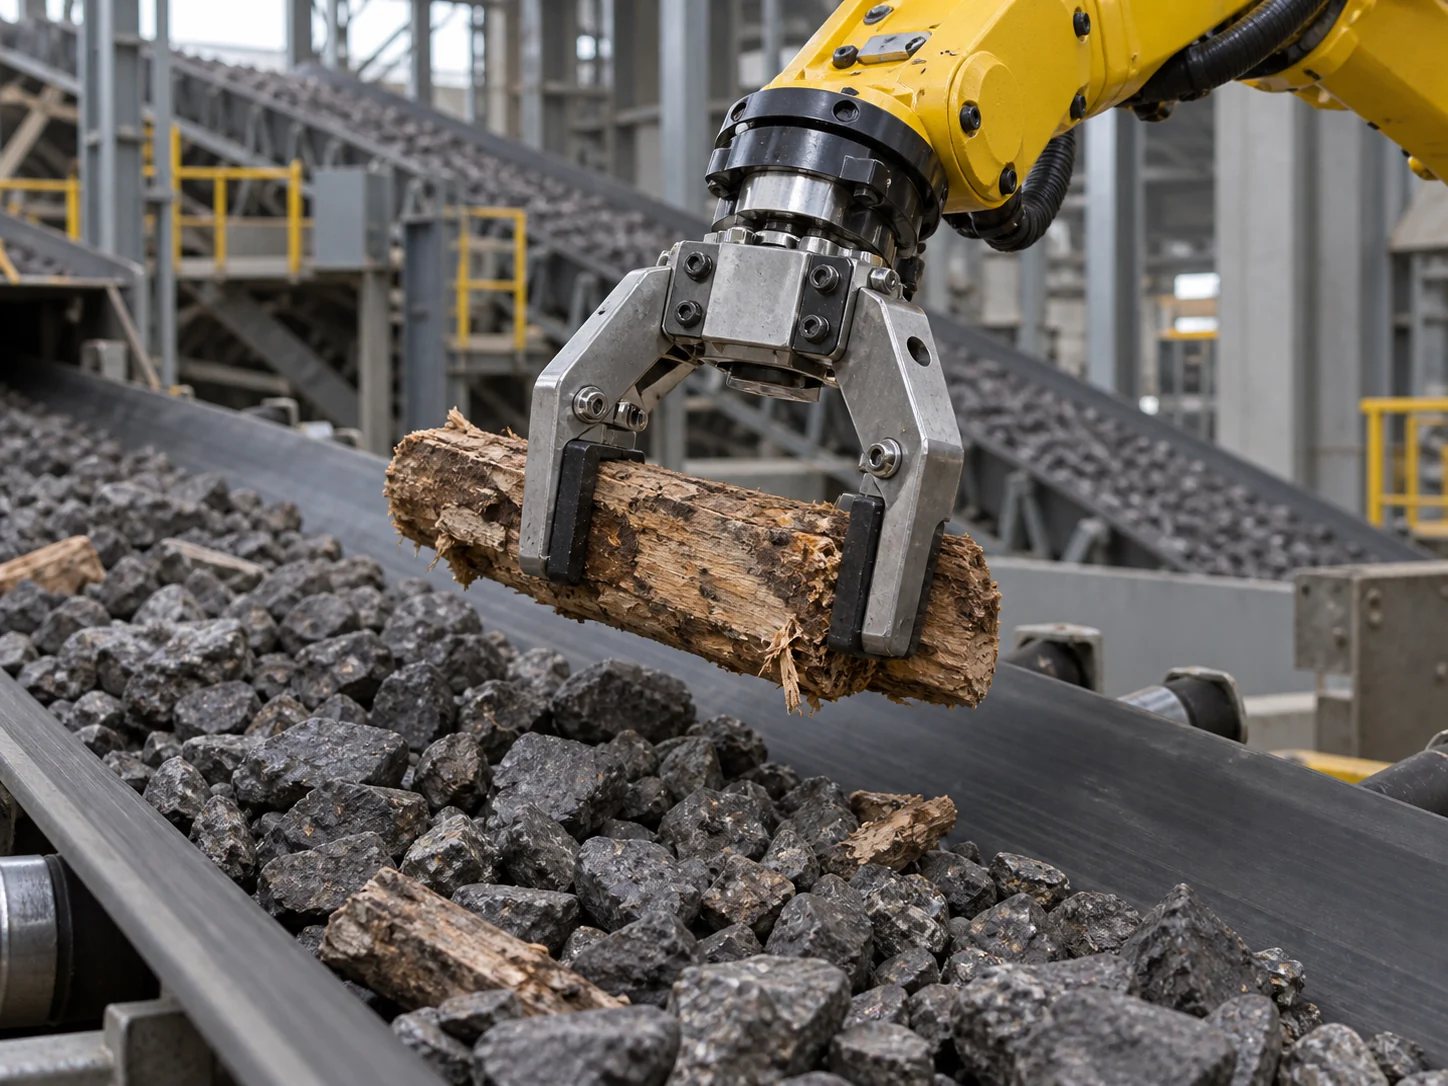
Mine conveyor foreign-object sorting
Identify visible wood, metal objects and woven bags on ore conveyors, then use speed tracking and robotic picking for online removal and sorted placement.
View capabilities and conditions of use
 Inspection and sorting
Multi-task vision inspection unit
For metal wire, shuttles, graphite V-grooves and small irregular parts, combine automatic feeding, vision localization, 2D/3D inspection, defect alerts and result traceability.
View capabilities and conditions of use
PROJECT INQUIRYTake your field requirements
Take your field requirements
into the next stage of planning.
Share the workpiece, site layout and target cycle time to discuss product selection, system configuration and validation.