PHYSICAL SAFETY ALIGNMENT
Physical-trust safety system
This safety-middleware R&D proposal adds action checks, risk fallback and evidence records. Joint validation with the robot and on-site safety-control chain is required.
Request configuration adviceFor plans and project enquiries, contact:
610015486@163.com · 18611193215 ·
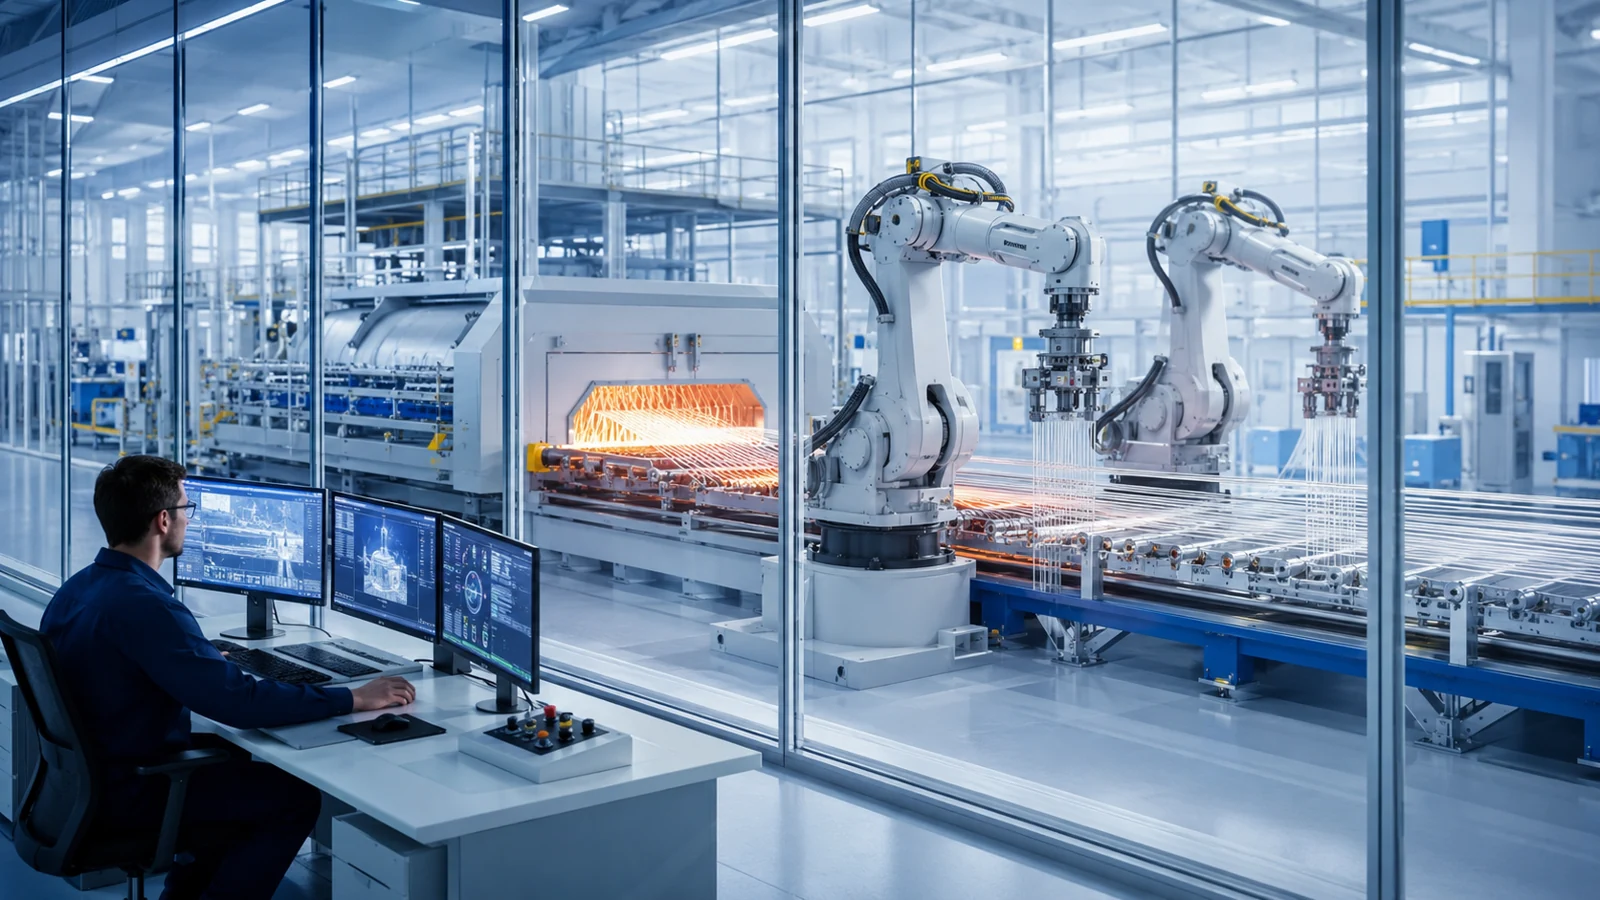 Application / concept illustration
Embodied Intelligence site editor · Content reviewed
Conditions to establish first
- Robot and control permissions
- Executable-task allowlist
- Risk and safe-fallback conditions
- Nature of the source material
- Technical product planning
- Configuration and pricing
- The source provides no verifiable current quotation. Confirm pricing against the site's task, configuration and validation scope.
- Conditions and limits of use
- Safety middleware under R&D planning. Validate its capabilities with the robot, control chain and specific application. No absolute-safety guarantee is made.
- Evidence still needed
- No publicly verifiable, application-specific safety report or certification was supplied. Absolute safety is not promised.
Sources and how to use them
01具身智能安全物理可信对齐系统-BP.pptx
This is a summary of the original proposal, not a claim that the site editor has manufactured, sold or delivered the equipment. Check configuration, engineering targets and measured results separately.
From a concept to field validation ↗Problems addressed
- Model-generated actions are uncertain
- Safety boundaries vary across complex sites
- Exception handling and responsibility tracing lack evidence
Core capabilities and configuration
Control barrier functions and reachable-set prediction
Dual-channel runtime safety fallback
Action and event evidence chains
Interfaces across robot platforms
Applications
Industrial human–robot collaborationPower-facility and equipment-room inspectionControlled bipedal-robot operationsHigh-risk task validation
Task workflow
01 · Define rules and boundaries02 · Check proposed actions03 · Execute or fall back safely04 · Record evidence and review
From concept to site
Safety middleware under R&D planning. Validate its capabilities with the robot, control chain and specific application. No absolute-safety guarantee is made.
EXPLORE MORE
Related products and systems
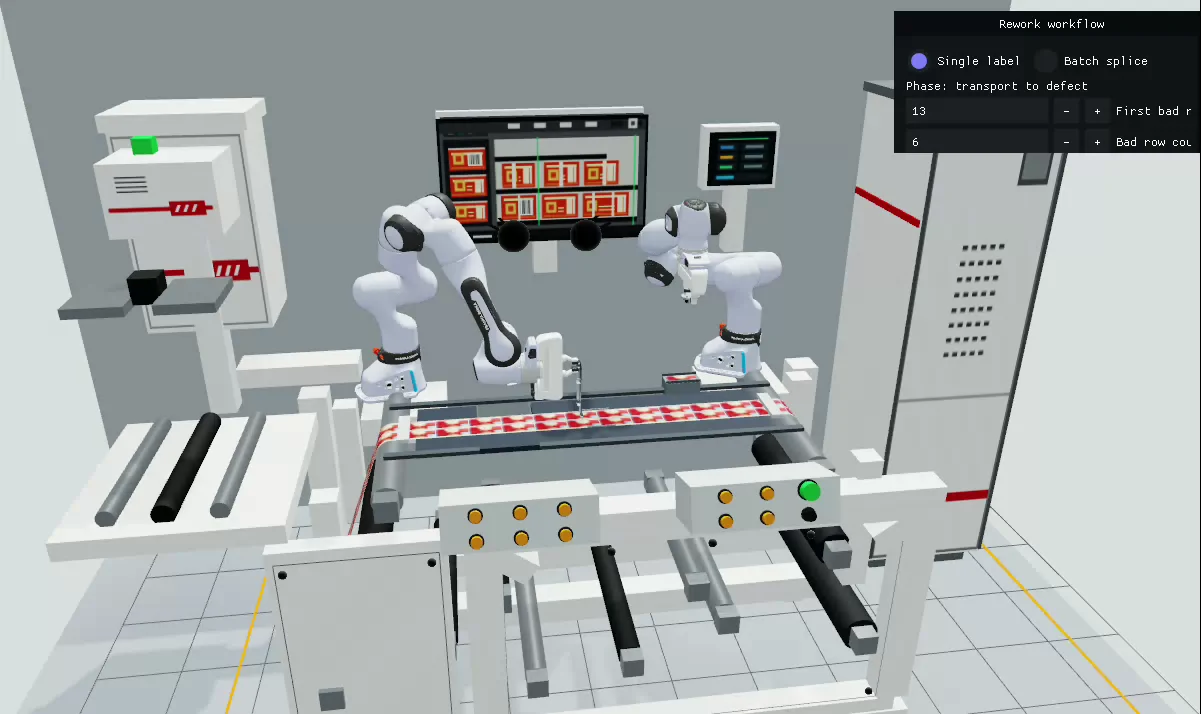 Intelligent platforms
High-fidelity physics simulation and training platform
Reconstruct scene, robot and sensor models, generate data and train policies in repeatable simulation, then develop transfer through pilot trials and real-robot feedback.
View capabilities and conditions of use
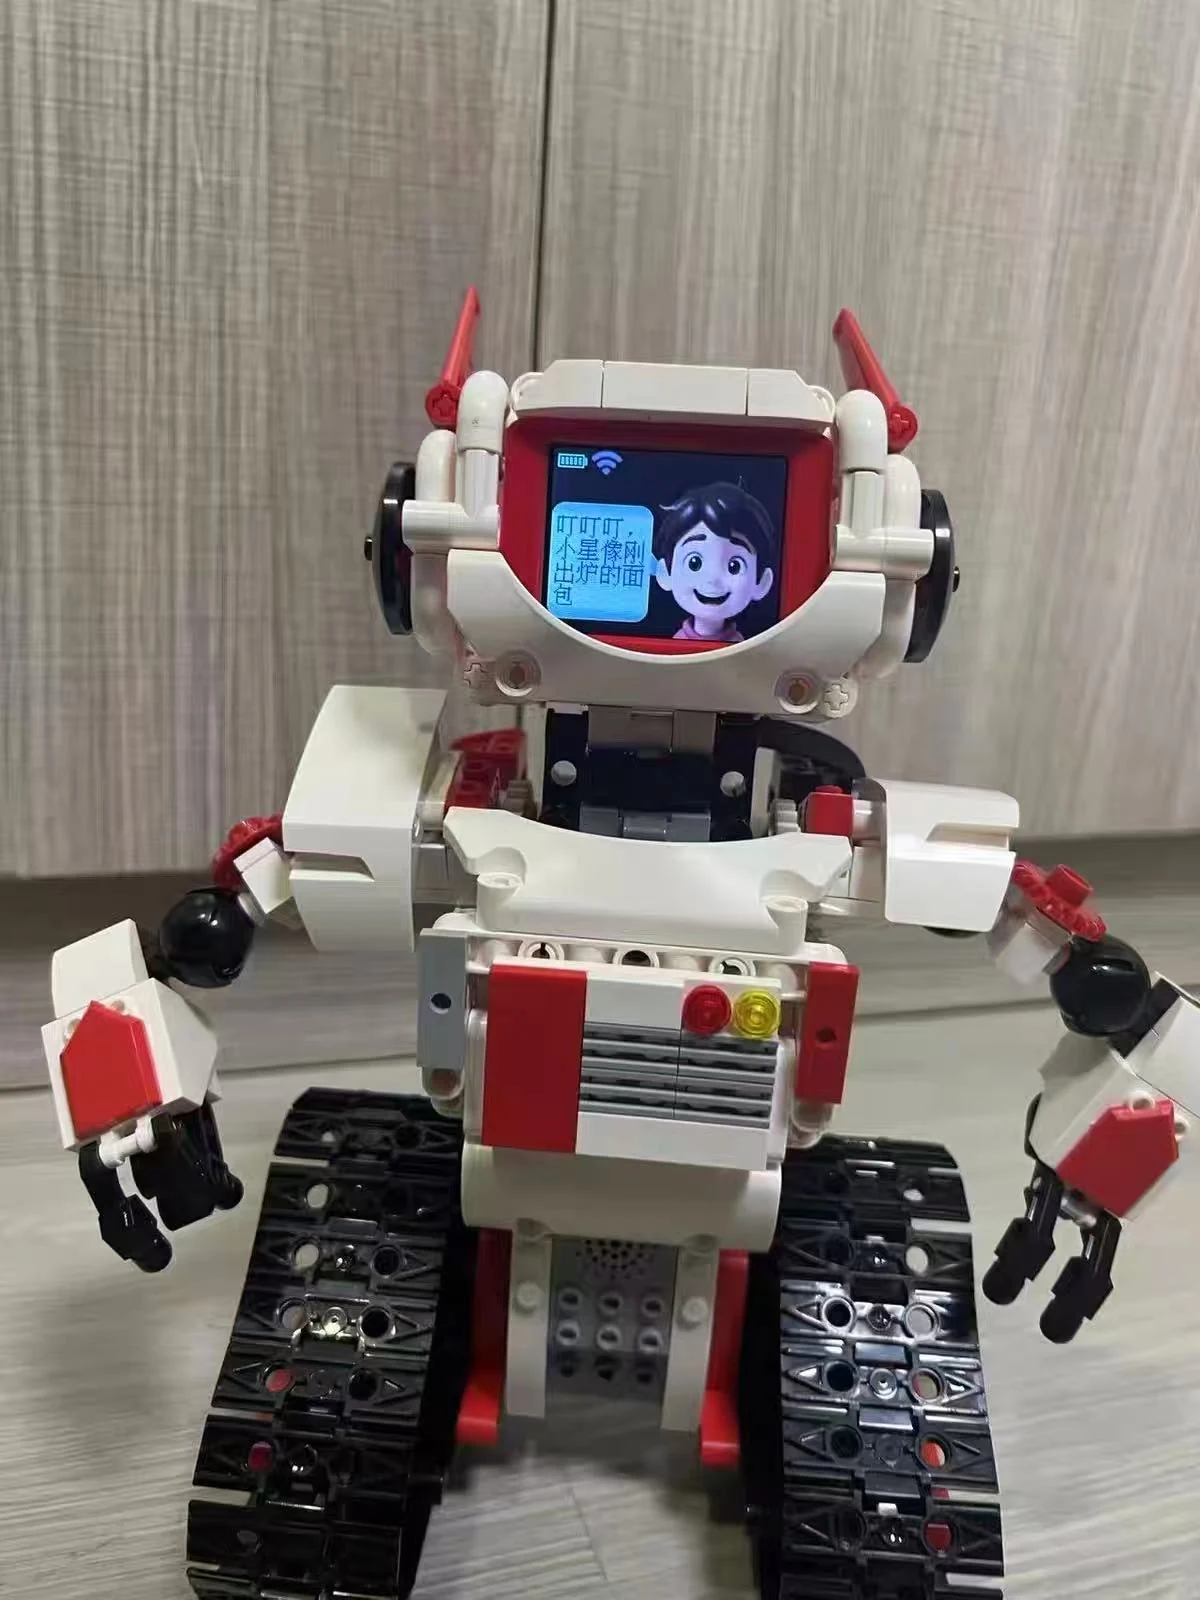 Intelligent platforms
Lingzhu AI Heart Brick
A common AI core brick connects buildable bodies, accessories and task stories, adding voice interaction, character feedback and activity records to children's constructions.
View capabilities and conditions of use
Intelligent platformsContractAI enterprise-private AI compliance workstation
A desktop workstation and local runtime support configurable enterprise workflows for preliminary contract review, internal-policy checks, cross-document consistency, human approval and report archiving.
View capabilities and conditions of use
PROJECT INQUIRYTake your field requirements
Take your field requirements
into the next stage of planning.
Share the workpiece, site layout and target cycle time to discuss product selection, system configuration and validation.