SCENARIO IN FOCUS
Detecting and removing foreign objects on mine conveyors
Identify visible wood, metal objects and woven bags on ore conveyors, then use speed tracking and robotic picking for online removal and sorted placement.
Request configuration adviceFor plans and project enquiries, contact:
610015486@163.com · 18611193215 ·
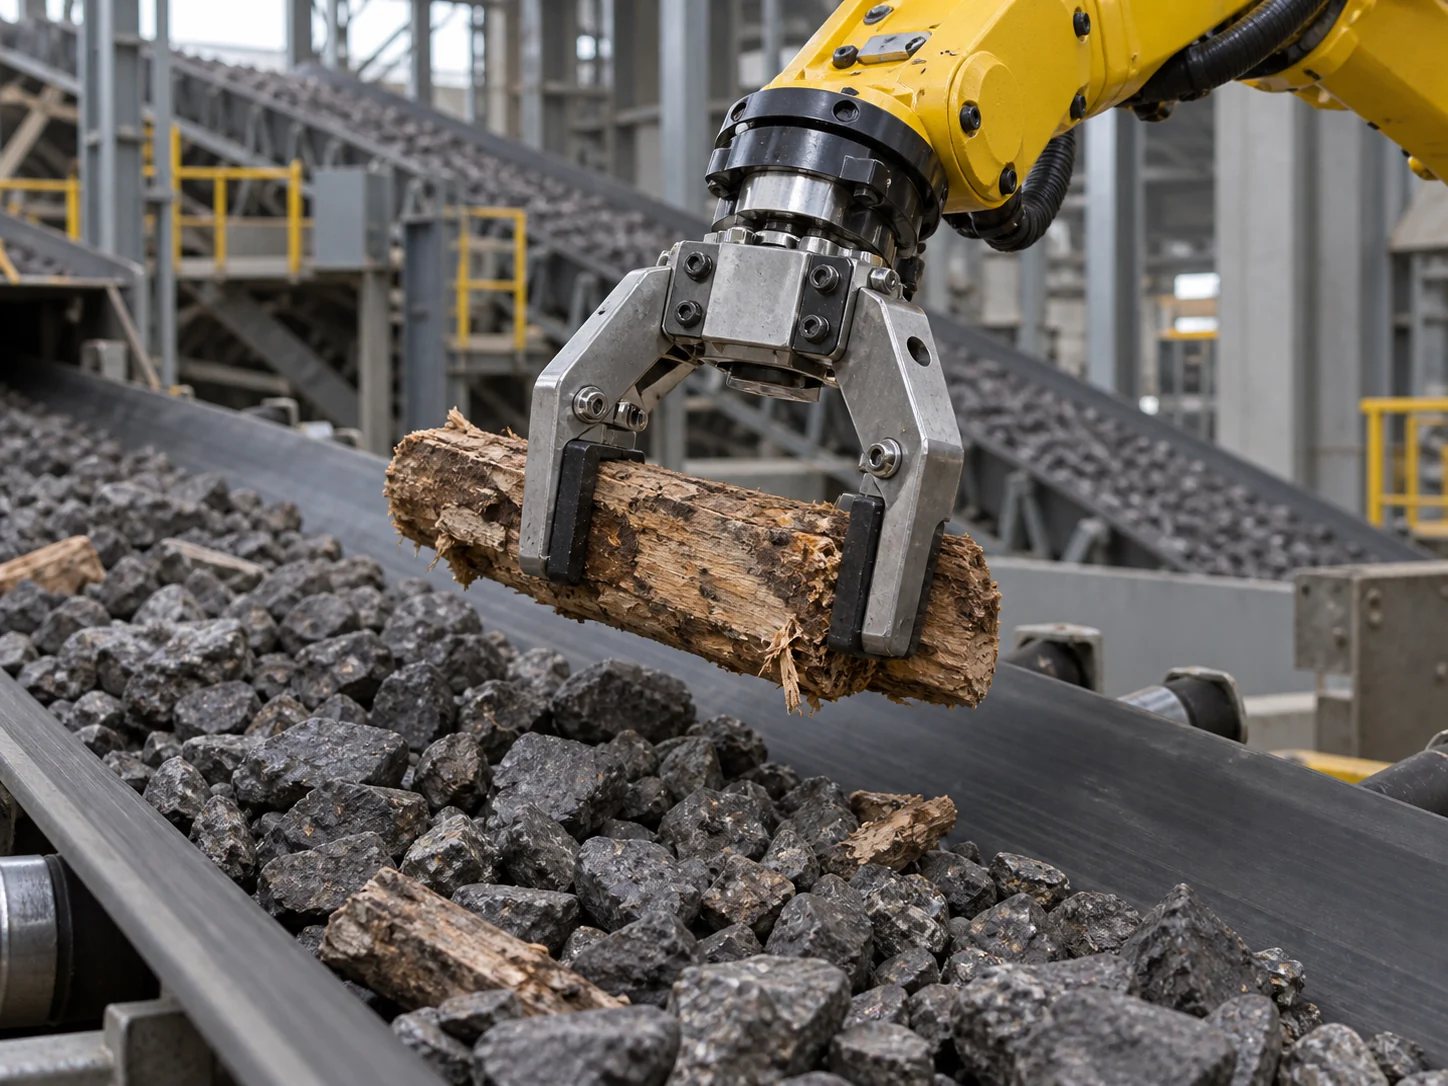 Application / concept illustration
Application requirements
Wood and foreign objects move with the belt. Detection, tracking, robot execution and conveyor safety interlocks must work together.
Concept design
Speed synchronization and moving-target tracking
Assess graspability and picking windows
Suitable grippers and sorted collection areas
Implementation considerations
First validate material shape, belt speed, occlusion and dust conditions. Then define picking strategy, operating scope and safety interlocks. Proposal targets are not proven production results.
Source: 17矿山杂物智能分拣解决方案_V1.8.pptx. Images illustrate applications or concepts from the original material.
PROJECT INQUIRYTake your field requirements
Take your field requirements
into the next stage of planning.
Share the workpiece, site layout and target cycle time to discuss product selection, system configuration and validation.