Conveyor foreign-object recognition
Use vision and target localization to design detection and picking workflows for wood, metal and other foreign objects.
Plan sensing, execution and safe takeover for mine inspection, conveyor debris removal and auxiliary tasks, developing robot applications and industry collaboration in stages.
Request configuration adviceFor plans and project enquiries, contact:
610015486@163.com · 18611193215 ·
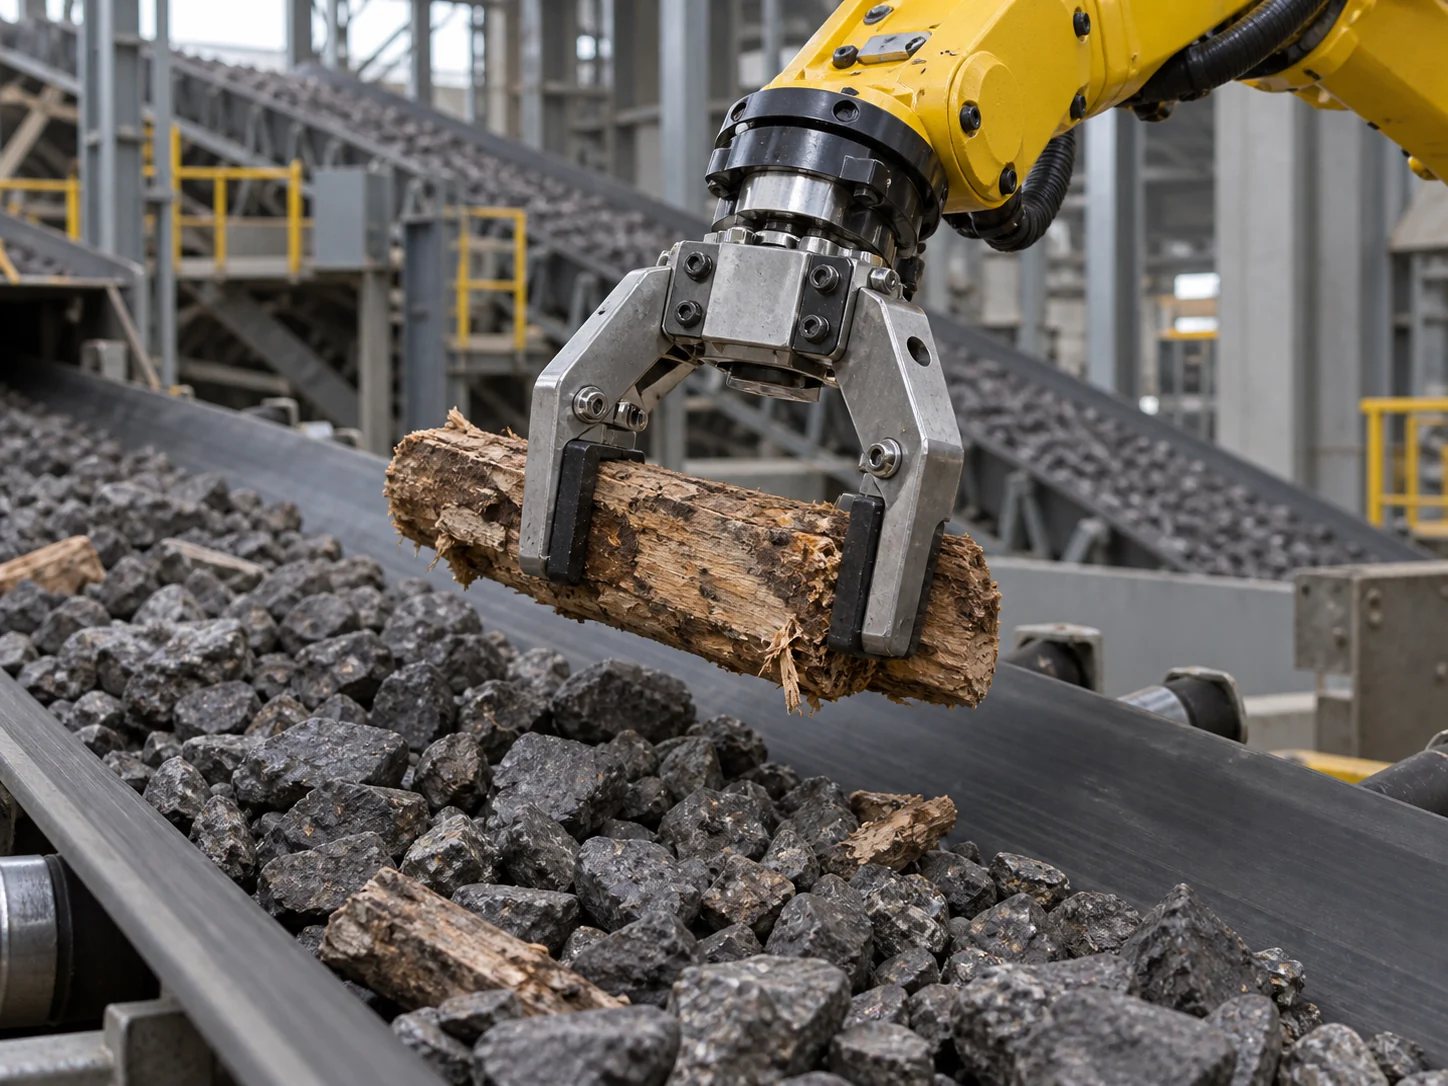 Application / concept illustration
Dust, humidity, poor lighting and moving conveyor targets place combined demands on sensing and execution. Protection, interlocks, communication coverage and human takeover must also be considered.
Use vision and target localization to design detection and picking workflows for wood, metal and other foreign objects.
Combine mobile robots, sensor payloads and edge computing according to mine access conditions and monitoring tasks.
Include site interlocks, remote monitoring and human takeover in task design, with explicit boundaries for exception responses.
Validate standard inspection and auxiliary applications first, then extend tasks and coordination based on field results.
Adapt concepts to site space, communication conditions, equipment interfaces, safety requirements and business workflows. Illustrations explain settings and configuration ideas only.
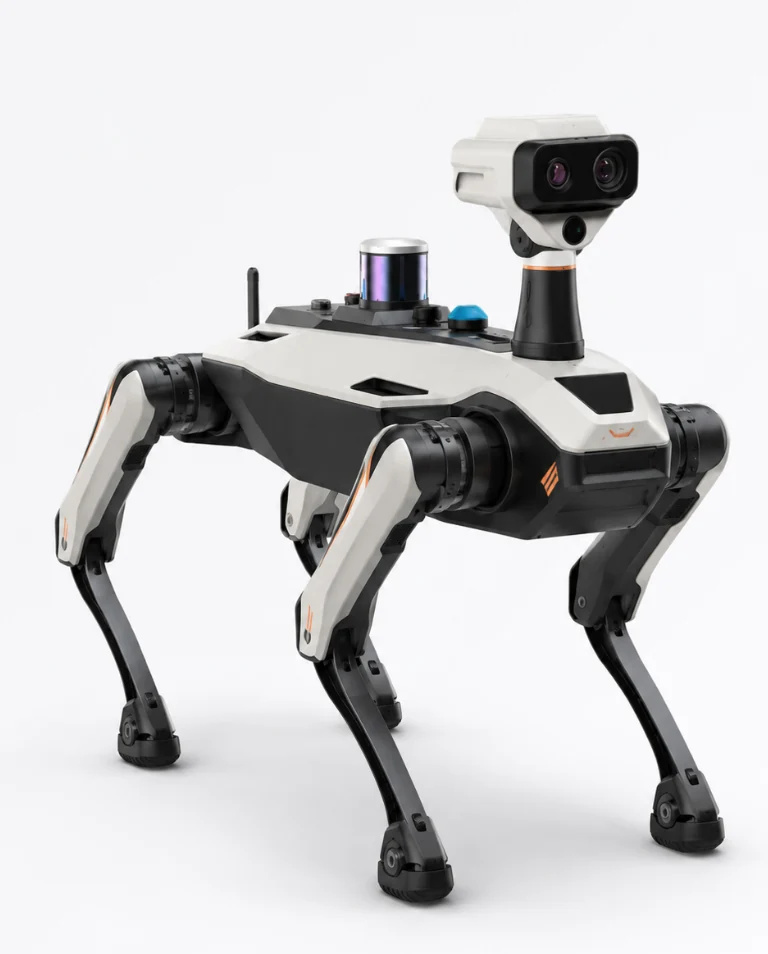 Specialized robots
Start with hazardous-work substitution and established transport and inspection tasks, then plan mine-wide coordination across robot equipment, a common intelligence platform and ongoing maintenance.
Inspection and sortingIdentify visible wood, metal objects and woven bags on ore conveyors, then use speed tracking and robotic picking for online removal and sorted placement.
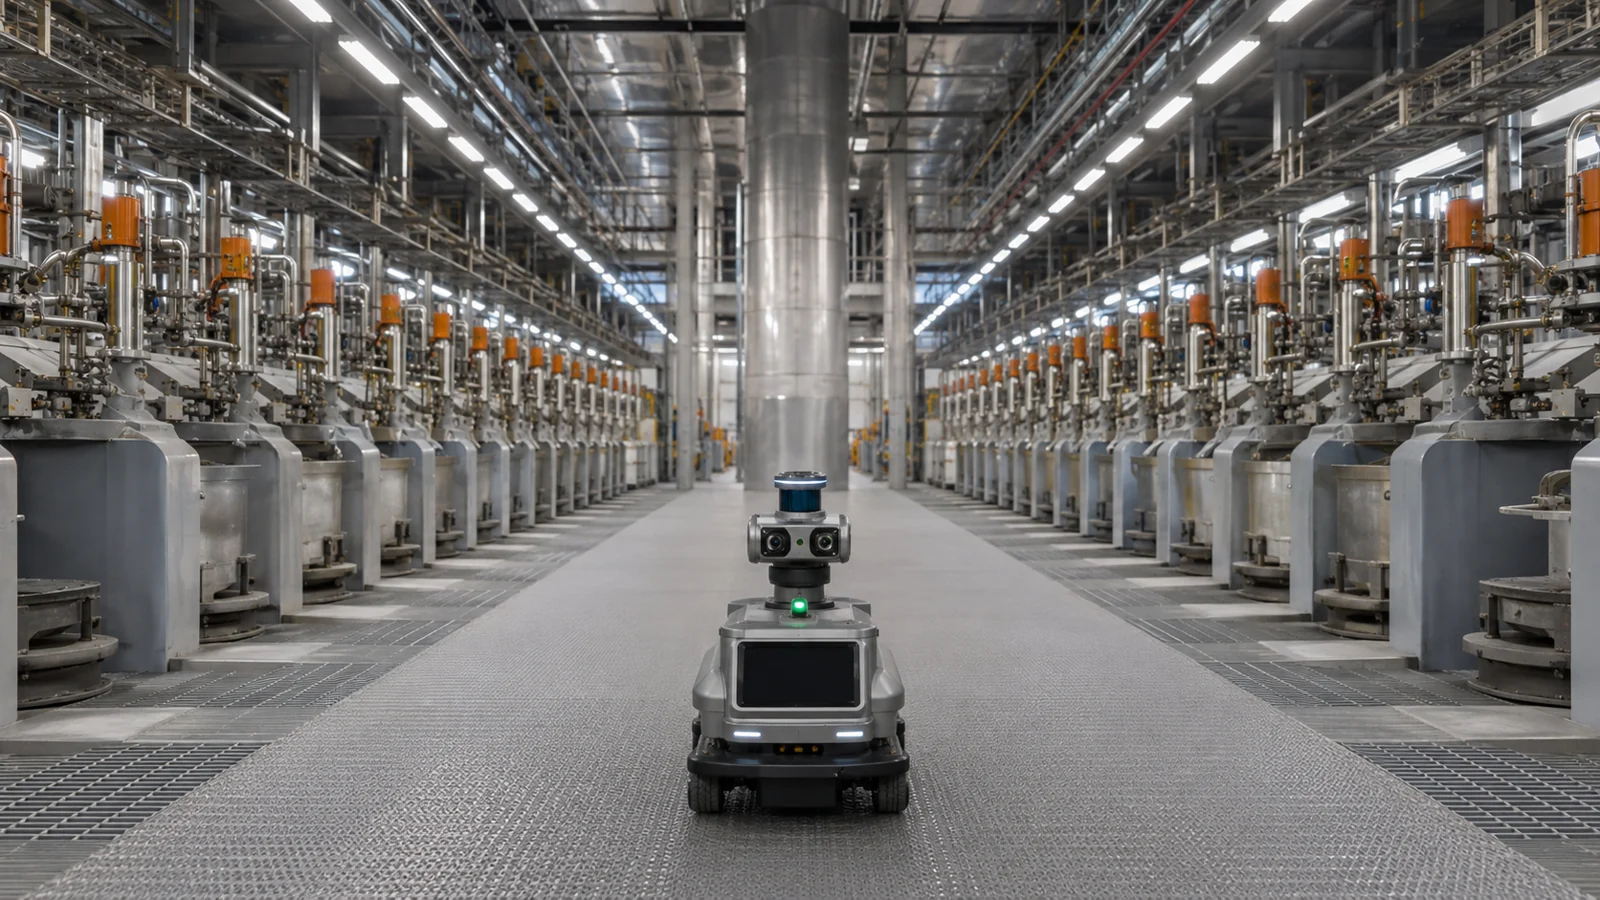 Intelligent platforms
Plan mining-robot industry collaboration, demonstration mines and shared technical platforms for high-altitude mountains, open pits and underground mines. Develop in stages: inspection first, transport expansion and extraction R&D.
Share the workpiece, site layout and target cycle time to discuss product selection, system configuration and validation.