FLEXIBLE ROBOTIC OPERATIONS
Robot task matrix for fiberglass twisting workshops
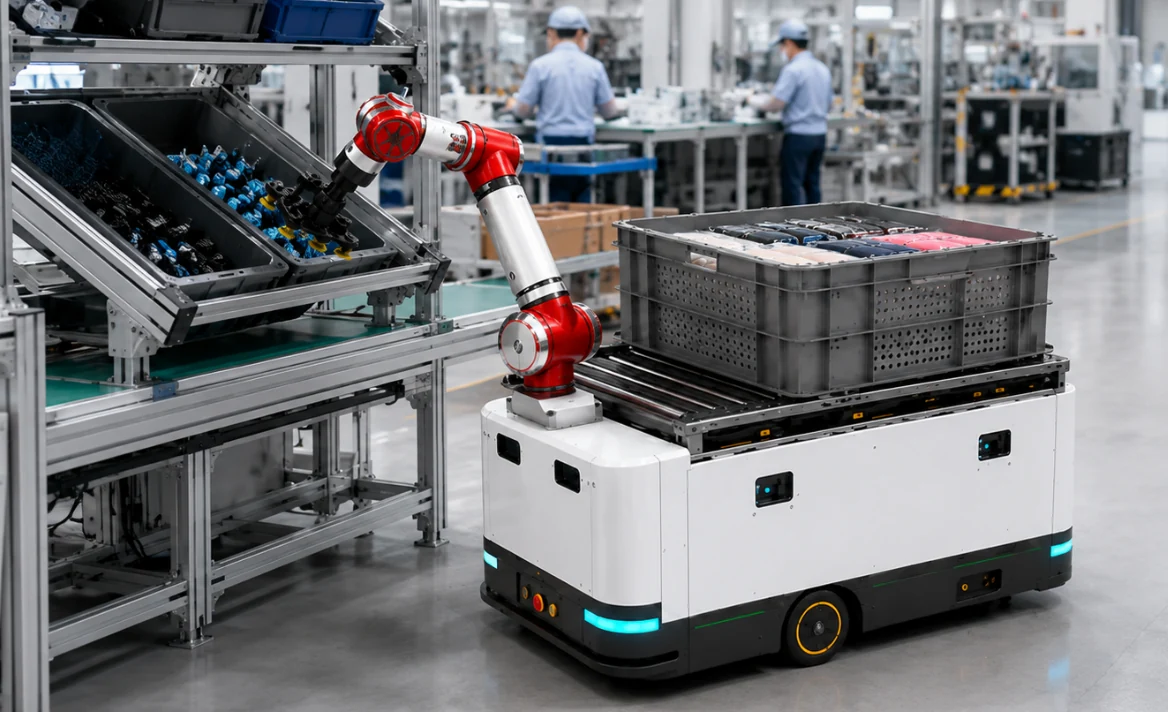
The twisting-workshop proposal separates inspection, raw-fiber handling and yarn-package operations into three robot task classes. Validate grippers, workstations and actions individually before discussing coordination and record updates.
Request configuration adviceFor plans and project enquiries, contact:
610015486@163.com · 18611193215 ·
 Application / concept illustration
Embodied Intelligence site editor · Content reviewed
Conditions to establish first
- Raw-fiber and yarn-package samples
- Gripping and force-control requirements
- Workstation modifications and MES/SCADA interfaces
- Nature of the source material
- Project proposal
- Configuration and pricing
- The source provides no verifiable current quotation. Confirm pricing against the site's task, configuration and validation scope.
- Conditions and limits of use
- Validate each material, gripper, workstation and action independently. Build the robot task matrix progressively around priority applications.
- Evidence still needed
- No evidence was supplied for a shared gripper across materials, one common cycle time or delivered-project acceptance.
Interpreting numbers in the material
The proposal configures robots for inspection, raw-fiber and yarn-package tasks. Quantities are to be determined separately.
Sources and how to use them
05玻纤捻线车间场景具身智能机器人产品矩阵项目解决方案V1.2-0525.pptx
This is a summary of the original proposal, not a claim that the site editor has manufactured, sold or delivered the equipment. Check configuration, engineering targets and measured results separately.
From a concept to field validation ↗Problems addressed
- Materials and actions vary considerably on site
- Repetitive operations coexist with quality checks
- Workstation information is disconnected from production systems
Core capabilities and configuration
Match lifting mechanisms and specialized end effectors
Vision localization and compliant force control
Anomaly review and human takeover
MES/SCADA integration and task traceability
Applications
Startup checksYarn-condition monitoringRaw-fiber bin handlingYarn-package and guide-hook operations
Task workflow
01 · Startup checks02 · Dispatch tasks03 · Locate and handle04 · Verify results05 · Update quality records06 · Improve the model
From concept to site
Validate each material, gripper, workstation and action independently. Build the robot task matrix progressively around priority applications.
EXPLORE MORE
Related products and systems
 Specialized robots
Municipal drain-pipe obstruction clearing
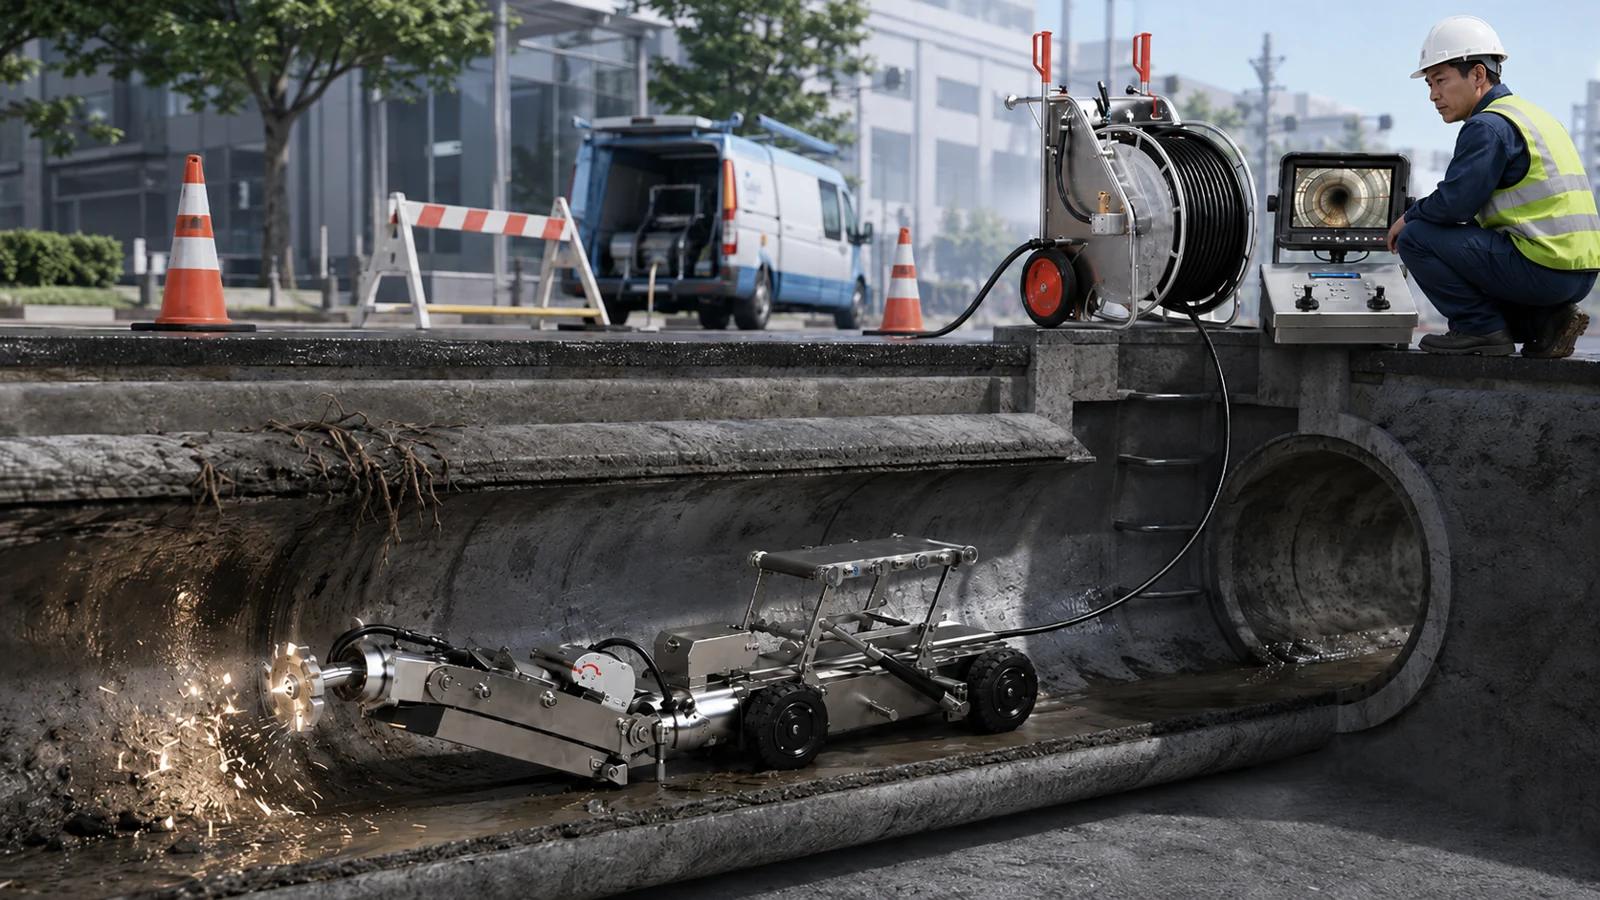
A surface operator controls the underground robot through wired communications and front/rear cameras. Interchangeable cutting heads remove roots, hardened deposits and solid blockages, with inspection images retained afterwards.
View capabilities and conditions of use
 Specialized robots
Coordinated robot systems for smart mines
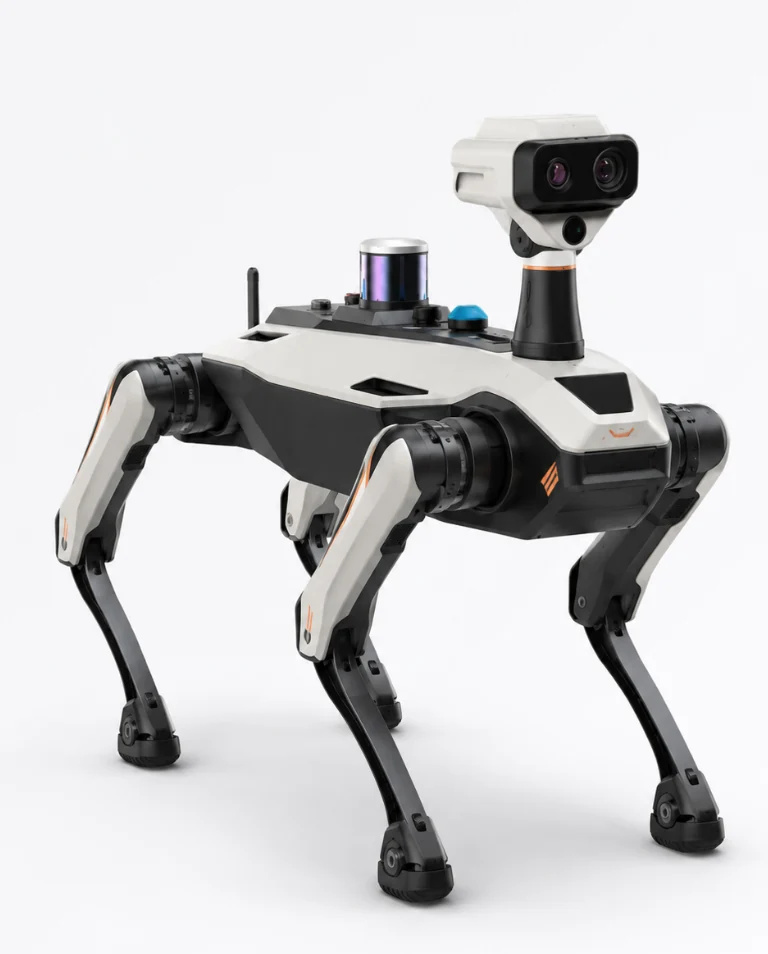
Start with hazardous-work substitution and established transport and inspection tasks, then plan mine-wide coordination across robot equipment, a common intelligence platform and ongoing maintenance.
View capabilities and conditions of use
 Specialized robots
A modular robotics approach for hospitals
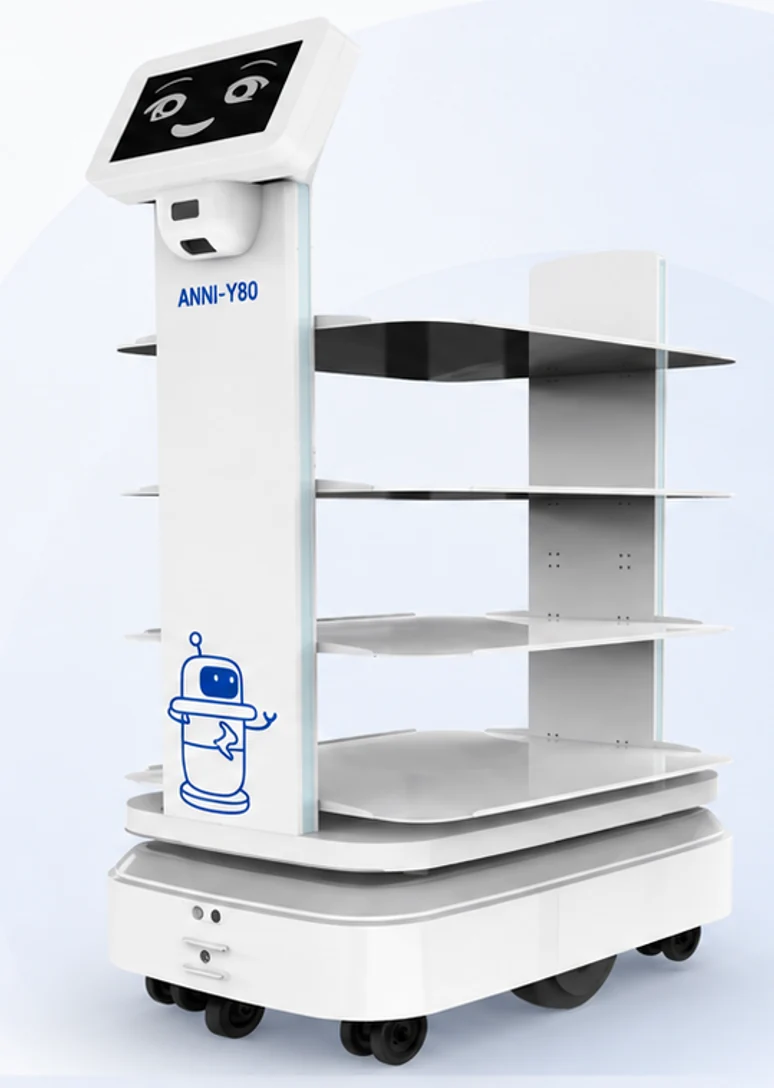
Combine medicine delivery, wayfinding, asset inventory and distribution-room inspection according to hospital space and business interfaces, with traceable robot services.
View capabilities and conditions of use
PROJECT INQUIRYTake your field requirements
Take your field requirements
into the next stage of planning.
Share the workpiece, site layout and target cycle time to discuss product selection, system configuration and validation.